Appearance
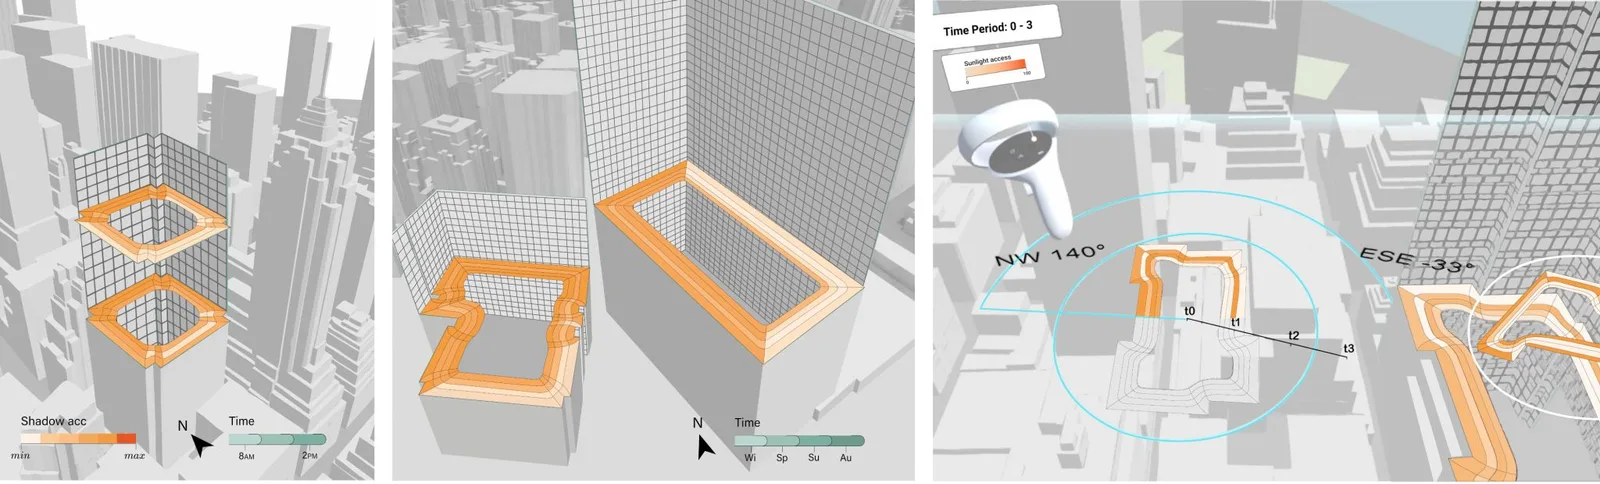
The paper “Occlusion-Free Conformal Lensing for Spatiotemporal Visualization in 3D Urban Analytics” was accepted to IEEE VR 2026 (TVCG track), held in Daegu, Korea, in March 2026.
The work presents an immersive lens visualization that supports the analysis of time-varying building data by mitigating self-occlusion and clutter in 3D urban analytics. The lens combines a view-dependent cutaway for de-occlusion with a temporal display, derived from a conformal mapping algorithm, embedded within the building.
It was led by Roberta Mota, with Julio D. Silva, Fabio Miranda, Usman Alim, Ehud Sharlin and Nivan Ferreira, a collaboration of the University of Calgary, the University of Illinois Chicago and Universidade Federal de Pernambuco. Preprint: arXiv 2602.03743.